Takahiro Maeda (前田 孝泰)I am a machine learning researcher at the Collaborative AI Laboratory, AI Digital R&D Center, Corporate Laboratory, Toshiba Corporation, where I develop enterprise vision-language models (VLMs) and AI agents. I completed the coursework of the doctoral program without a degree (単位取得満期退学) at Toyota Technological Institute (TTI) in 2025, advised by Prof. Norimichi Ukita. I also earned my M.Eng. in electronics and information engineering at TTI in 2021 and B.Eng. in 2019 while working with Norimichi Ukita. During my studies, I was a research intern at the Robotics Institute, Carnegie Mellon University (2024) and the Frontier Research Center, Toyota Motor Corporation (2023), and a visiting student at TTI-Chicago (2019). My research interests include computer vision, robotics, human motion prediction, and multimodal models, with a long-term interest in robust perception for intelligent assistive robots. I got a Certified Care Worker (介護福祉士) national qualification license on April, 2022. |
|
Research |
|
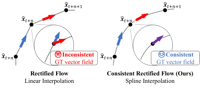
Continuously-indexed Flows for Fast Inference and Updating of Trajectory-prediction DensitiesTakahiro Maeda and Norimichi Ukita Neurocomputing, 2026 paper / code / website / Journal extension of FlowChain (ICCV 2023). |
|
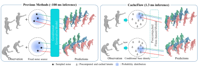
CacheFlow: Fast Human Motion Prediction by Cached Normalizing FlowTakahiro Maeda, Jinkun Cao, Norimichi Ukita, and Kris Kitani Transactions on Machine Learning Research (TMLR), 2026 arxiv / paper / code / website / Work done during the research internship at Robotics Institute, Carnegie Mellon University in 2024. |
|
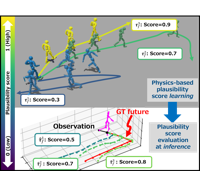
Physical Plausibility-aware Trajectory Prediction via Locomotion EmbodimentHiromu Taketsugu, Takeru Oba, Takahiro Maeda, Shohei Nobuhara, and Norimichi Ukita CVPR, 2025 arxiv / code / website / |
|
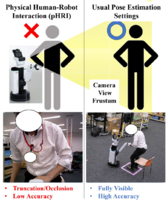
Multimodal Active Measurement for Human Mesh Recovery in Close ProximityTakahiro Maeda, Keisuke Takeshita, Norimichi Ukita, and Kazuhito Tanaka IEEE Robotics and Automation Letters (RA-L), 2024 arxiv / video / code / Work done during the internship at Frontier Research Center, Toyota Motor Corporation in 2023. |
|
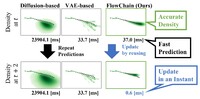
Fast Inference and Update of Probabilistic Density Estimation on Trajectory PredictionTakahiro Maeda and Norimichi Ukita ICCV, 2023 arxiv / code / poster / website / |
|
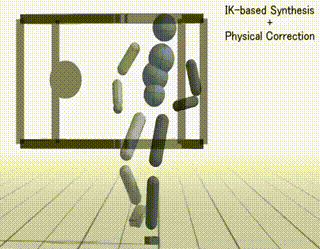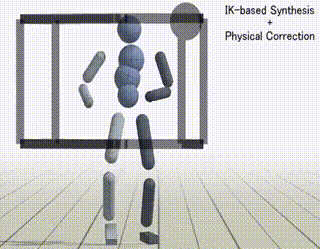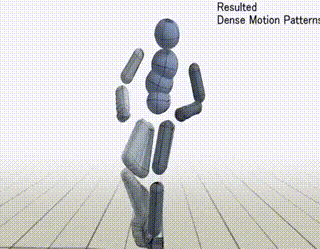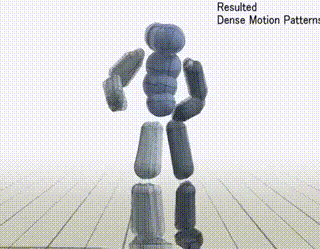
MotionAug: Augmentation with Physical Correction for Human Motion PredictionTakahiro Maeda and Norimichi Ukita CVPR, 2022 arxiv / video / code / IEEE Nagoya Section Conference Presentation Award 2023 |
|
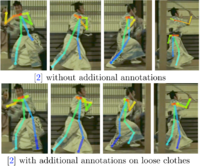
Human Pose Annotation Using a Motion Capture System for Loose-Fitting ClothesTakuya Matsumoto, Kodai Shimosato, Takahiro Maeda, Tatsuya Murakami, Koji Murakoso, Kazuhiko Mino, and Norimichi Ukita IEICE Transactions on Information and Systems 103 (6), 1257-1264, 2020 paper / |
|
Automatic human pose annotation for loose-fitting clothesTakuya Matsumoto, Kodai Shimosato, Takahiro Maeda, Tatsuya Murakami, Koji Murakoso, Kazuhiko Mino, and Norimichi Ukita 16th International Conference on Machine Vision Applications (MVA) Best Poster Award, 2019 paper / |
Other ProjectsThese include unpublished research works and contributed articles. |
|
Tutorial on Normalizing Flow and Flow Matching on CV Frontier, Autumn 2024
|
|
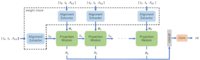
NTIRE 2021 Challenge on Burst Super-Resolution: Methods and ResultsTakahiro Maeda and Kazutoshi Akita challenge 2021-07-01 paper / code / The report of 2021 NTIRE Burst Super Resolusion challenge. We won 4th Place. |
|
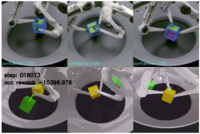
Grasp and Motion Planning for Dexterous Manipulation for the Real Robot ChallengeTakuma Yoneda, Charles Schaff, Takahiro Maeda, and Matthew Walter challenge 2021-01-08 arxiv / paper / code / I participated in the 2020 Real Robot Challenge with M. Walter’s group at TTI-Chicago. We won 1st place in Phases 2 and 3. |
Honors & Awards
Services
|
|
Design and source code from Jon Barron's website |